Transportation is a key factor in modern society. Statistically, it’s also one of the main causes of death and injury: according to the World Health Organization, approximately 1.16 million people die in road traffic crashes every year. Safety is therefore a priority for the whole industry, especially as cities grow and the number of vehicles rises. Computer Vision in transportation safety is one of the tools that can help reduce that toll.
Below we look at where Computer Vision models are actually used for transport safety today, which regulations now require camera-based safety systems in new vehicles, the techniques behind them, how such systems are evaluated, where they fail, and what wider 5G coverage does and does not change.
How Is Computer Vision Used in Transportation?
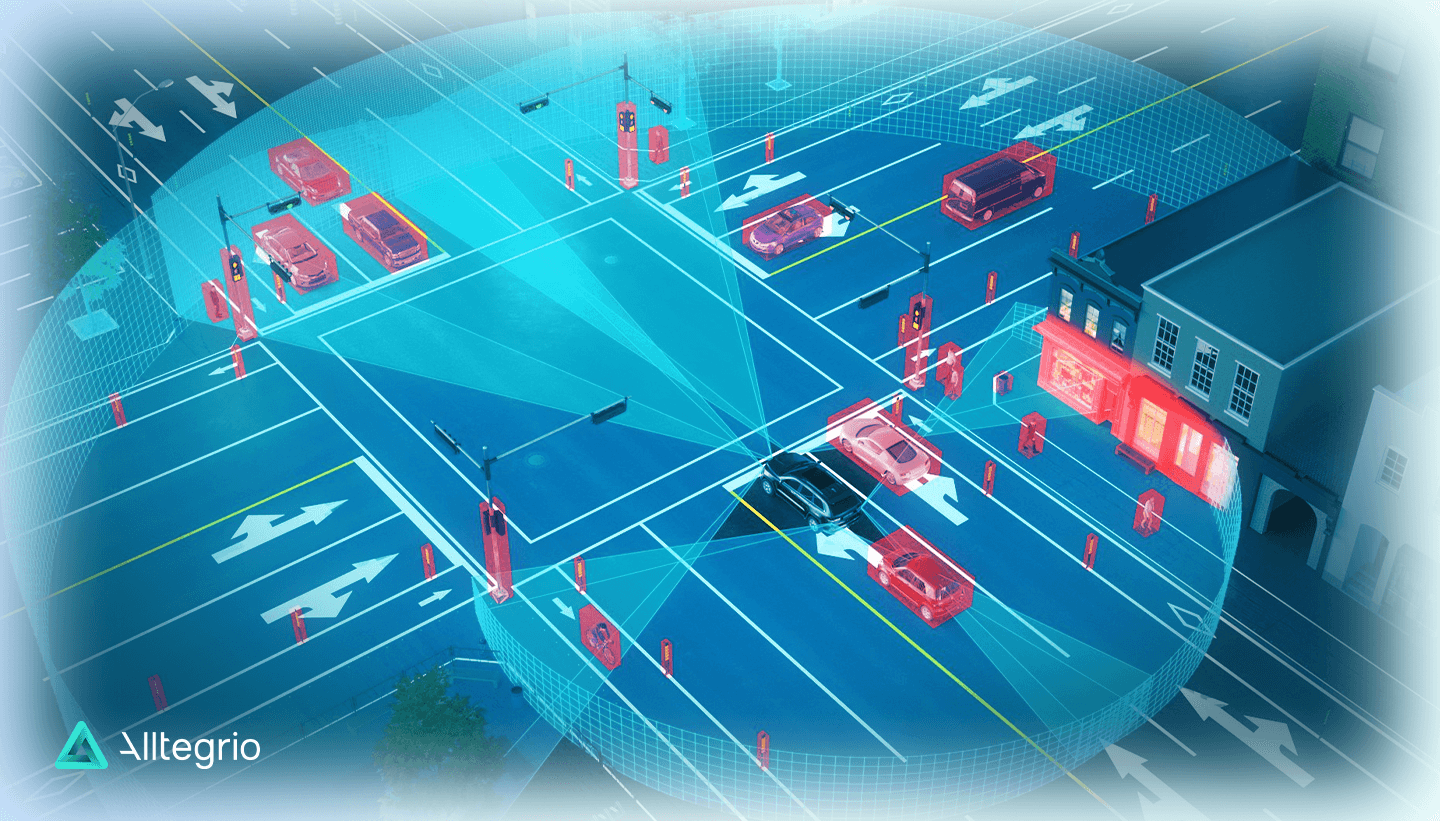
Computer Vision is the use of models, today mostly deep neural networks, to detect, classify, track and measure objects in images and video. In transportation it turns camera feeds into structured events: a vehicle count, a pedestrian in a lane, a driver whose eyes have been closed for two seconds. It’s used in tools ranging from traffic monitoring and vehicle recognition to accident detection systems.
| Application | AI and Transportation Implementation | Benefits |
|---|---|---|
| Real-Time Traffic Condition Analysis | Cameras along the road and at junctions take pictures and videos, from which algorithms infer flow conditions regarding the intensity of movement and congestion. | The collected information enables timely intervention to alter signal timings and other related issues. Integrating Computer Vision with Machine Learning algorithms for Predictive Analytics further provides the added capability to project traffic congestion based on previous data, weather conditions, and special events, proactively managing traffic. |
| Advanced Driver Assistance Systems (ADAS) | Integrated features include lane departure warning, adaptive cruise control, and automatic emergency braking. | Such systems continually observe the surroundings using computer vision to make driving safer by enhancing decision-making. See a case study example here. |
| Self-Driving Vehicles | Cameras and Computer Vision are used to identify pedestrians, cyclists, and other cars in real-time as the vehicle navigates. | Self-driving vehicles already carry passengers in limited areas, under close regulatory oversight and with remote monitoring. As these systems advance, they use Deep Learning algorithms that enhance their capabilities for object detection and classification in complex scenes, making them more reliable and effective. |
| Transportation Infrastructure Inspection & Maintenance | Drones with high-resolution cameras can fly over bridges, highways, and tunnels to obtain detailed images. These are used to automatically assess the structural integrity of those structures. | This technology speeds up the whole process and minimizes the risks linked with human inspections in hazardous areas. Visual data allows engineers to identify possible issues, such as cracks or corrosion, that could lead to serious problems if not addressed, helping make transportation infrastructure safer and more reliable. |
What Transportation Safety Problems Can Computer Vision Solve?
Many Computer Vision projects focus on safety challenges in transportation systems. Used well, this technology can help reduce accidents, injuries and fatalities.
At the moment, Computer Vision models are most widely applied in:
- Accident Detection
The system can quickly detect accidents and alert emergency services to reach the site much faster. - Speed Limit Enforcement
Computer Vision can be applied in automated speed detection systems, which capture vehicle speeds and help enforce traffic laws. - Object Detection
AI object detection technology can identify obstacles on the road, such as debris or broken-down vehicles, to prevent collisions and create safer driving. - Driver Behavior Monitoring
In-vehicle cameras enable the analysis of driver actions, helping identify risky behaviors so they can be corrected in time. Drivers should be told what the cameras record, how the footage is used and who can see it.
Each of these works best as part of a wider process: an accident alert is useful only if a dispatcher acts on it, and speed enforcement data only if it reaches the people who set limits and design roads. For pedestrian safety, a vision system detects crosswalks and tracks the people on or near them. It can alert the driver when a pedestrian is near, reducing the chances of an accident, especially at busy junctions. It can also be integrated with smart traffic signals to optimize traffic flow, reducing congestion and the risk of rear-end collisions.
Computer Vision in public transport systems can also improve passenger safety. For example, camera systems can detect a person on the tracks, a fall on an escalator or overcrowding on a platform and alert staff in real time. Such systems should be limited to specific safety events, announced to passengers with clear signage, and run within privacy law, with footage kept only as long as needed. Safer stations and vehicles make public transport a more attractive choice.
How Can Computer Vision Impact the Safety of Transportation Systems?
The impact is largest where cameras replace a check that humans do poorly over long periods: watching a driver’s eyes for hours, scanning a lane for a pedestrian in low light, or reviewing thousands of hours of intersection video for near-misses. Regulators have recognized this, and several camera-based functions have moved from optional extras to legal requirements:
| Regulation | What it requires | Timing |
|---|---|---|
| EU General Safety Regulation (EU) 2019/2144 | Driver drowsiness and attention warning, advanced driver distraction warning (ADDW, typically an in-cabin camera tracking head and eye movement), intelligent speed assistance, emergency braking and other systems | ADDW for new vehicle types from July 2024 and for all new vehicles from July 2026 |
| US FMVSS No. 127, NHTSA final rule of 2024 | Automatic emergency braking, including pedestrian AEB, on light vehicles | Compliance required by September 1, 2029 |
These rules matter beyond carmakers. Fleets, insurers and city traffic departments increasingly work with the same kinds of data, and the test procedures written for regulation are a useful model for how any safety-related vision system should be evaluated.
On the infrastructure side, the shift is from reacting to crashes to analyzing near-misses. Video analytics at intersections can count conflicts, such as hard braking or a vehicle passing close to a pedestrian, which happen far more often than crashes. That gives traffic engineers evidence to fix a dangerous junction before the injury statistics accumulate.
Machine Learning lets these Computer Vision systems improve over time. In a safety system this does not happen on its own: engineers collect the cases the system got wrong, label them, retrain the model and test the new version on a fixed set of scenarios before it is deployed. This controlled cycle turns field experience into more effective safety interventions without introducing untested behavior.
In commercial fleets, road-facing and driver-facing cameras combined with telematics flag events such as harsh braking, tailgating, phone use or a rolling stop. The useful output is not the raw alert stream but a short list of reviewed events per driver, which feeds targeted coaching. Two design points decide whether drivers accept it: events are reviewed by a person before they count against anyone, and drivers can see their own footage.
Also, cameras together with vehicle sensors can help detect some malfunctions, such as worn or deflated tires, and may trigger on-time maintenance warnings that could potentially avoid an accident. More on using AI-powered technologies for predictive maintenance in this article.
Inside the vehicle, pedestrian and cyclist detection is the core of pedestrian AEB. Outside it, the same detection runs on roadside cameras; the section on pedestrian safety below covers both.
How Can Computer Vision Be Used to Improve Driver Safety?
| Solution | Tech base | How it’s used |
|---|---|---|
| Monitoring driver attentiveness in-cabin | Connected cameras | Cameras can detect drowsiness or distractions caused by phone use and alert the driver to take corrective action. Such systems are designed to intervene before minor lapses lead to serious accidents. |
| Providing heads-up alerts | Augmented Reality applications | AR applications integrate Computer Vision with the real world to supply drivers with helpful information. For instance, displays can project navigation directions or upcoming hazards directly onto the windshield so the driver can keep his eyes on the road. |
| Computer Vision for ADAS | A network of cameras and sensors | The system monitors the vehicle’s surroundings for obstacles, pedestrians, and other vehicles. When analyzed in real-time, this information enables ADAS to perform functions like automatic emergency braking, lane-keeping assistance, and adaptive cruise control. |
Make Your Drivers Safer
Learn how to use the data from Computer Vision in transportation systems you already run to improve your drivers’ and fleet’s safety.
How Can Computer Vision Enhance Pedestrian Safety?
Computer Vision enhances pedestrian safety in three places: in the vehicle, at the crossing and in the planning office. That focus is justified by the numbers: the WHO reports that more than half of all road traffic deaths are among vulnerable road users, meaning pedestrians, cyclists and motorcyclists.
- In the vehicle. Pedestrian AEB uses a camera, often fused with radar, to detect a person in the vehicle’s path and brake if the driver does not. Night-time and partially hidden pedestrians, such as someone stepping out from between parked cars, are the hardest cases and are explicitly covered by regulatory test procedures.
- At the crossing. Cameras at crosswalks detect people waiting or crossing and can trigger flashing warning beacons for approaching drivers or hold a turning signal while someone is still in the crosswalk.
- In the planning office. Aggregated, anonymized counts show where people actually cross, including mid-block crossings far from a marked crosswalk. That evidence supports decisions about where to add crossings, refuges or lower speed limits.
Additionally, Computer Vision models could enable smart traffic lights to automatically adjust their cycle timing in correspondence with real-time pedestrian activity. Analyzing foot traffic, the signal can extend crossings to accommodate high-volume times so people can cross safely and quickly. This dynamic adjustment enhances safety and helps with traffic flow since cars are less likely to be stopped unnecessarily.
Besides real-time monitoring, accident analysis is another area where applying Computer Vision in transportation safety pays dividends. Data from various intersections helps authorities find some common factors leading to or surrounding incidents involving pedestrians. The information gathered thereafter can suggest installing signs at specific places, improving lighting, or even redesigning road layouts for better pedestrian safety. This is where data-driven approaches can provide valuable insights for urban planning and policy-making to build a culture of safety in urban areas.
How Can Computer Vision Optimize Traffic Flow and Reduce Congestion?
Traffic congestion is a barrier to safety and efficiency on roads and transportation systems. Enhancing transportation safety with Computer Vision technologies starts with optimizing traffic flow and minimizing congestion.
This technology allows for real-time traffic analysis and can provide data on vehicle counts, speeds, and congestion points. This information enables traffic management systems to dynamically adjust signal timings, redirect traffic, and even deploy personnel where and when necessary in critical areas.
Computer Vision models enhanced by Predictive Analytics look at historical trends and predict future traffic. This lets planners act before predicted congestion builds up, which helps both safety and efficiency.
Connected vehicles add a second data source. Signal phase and timing messages broadcast from intersections let vehicles know when a light will change, and aggregated vehicle data shows where queues form. Combined with roadside camera counts, a traffic management center sees both what is happening at the junction and how traffic is approaching it.
The safety link is direct: congestion produces rear-end collisions at queue tails and risky behavior from frustrated drivers. Detecting a queue that extends back onto a highway and warning approaching traffic, through variable message signs or in-vehicle alerts, addresses one of the classic high-severity crash types.
How Will the Integration of 5G Impact the Deployment of Computer Vision in Transportation?
5G technology mainly improves how Computer Vision data moves, not how well it is analyzed. Its higher bandwidth and lower latency make it practical to send camera data and alerts between vehicles, roadside units and traffic centers in near real time.
For example, connected vehicles can share warnings about road conditions, obstacles and traffic flow with each other and with the infrastructure. This vehicle-to-everything communication gives drivers and systems earlier notice of hazards beyond their line of sight.
With 5G, roadside cameras can stream high-definition video to a central platform, or send only detection results when the analysis runs on the camera itself. Network capacity does not make object detection more accurate. Accuracy depends on the model, the training data and testing in real conditions.
Safety-critical ADAS functions, such as automatic emergency braking and driver drowsiness alerts, run on processors inside the vehicle, because they cannot depend on network coverage. 5G adds context from outside the vehicle, for example a warning about a stopped car around a bend. Together, onboard detection and shared warnings give drivers more time to react and reduce the possibility of collisions.
The impact of 5G on Computer Vision in transportation goes beyond single vehicles and extends into smart infrastructure. Incorporating traffic lights, road signs, and cameras into one cohesive network feeds data to a central platform. This will optimize traffic, reduce congestion, and improve general urban mobility. For instance, Computer Vision models can adjust traffic lights in real time to the current flow, which shortens waiting at intersections. This increases the efficiency of transport systems and reduces emissions, lowering the carbon footprint.
Road Safety Systems
Turn the safety data your fleet and cameras already collect into reports, alerts and decisions your team can act on.
What Are the Key Computer Vision Techniques Used in Transportation Safety Apps?
When implementing Computer Vision and imaging in intelligent transportation systems, developers usually rely on the following techniques:
- Image Segmentation
This technique divides an image into multiple segments, allowing systems to identify and focus on relevant objects like vehicles, pedestrians, and signs. By isolating these elements, transportation safety apps can better analyze the environment and make real-time decisions. - Object Recognition
This technique is used to improve overall situational awareness by identifying cars and trucks as well as bicycles, motorcycles and animals on the road. - Optical Character Recognition
OCR is used to read text from images, such as license plates and the text on road signs. Traffic sign recognition in ADAS combines it with object classification to identify speed limits, warning signs and direction indicators, so the system can warn the driver and help them obey traffic laws. - Driver Monitoring (Facial Analysis)
Driver monitoring systems analyze the driver’s face for in-cabin safety. They track eye closure, gaze direction and head position to detect signs of fatigue or distraction and send alerts to keep the driver focused on the road. This is facial analysis, not facial recognition: the system does not need to know who the driver is. - Neural Networks
Almost every technique above is implemented with deep neural networks: convolutional or transformer-based detectors for objects, segmentation networks for drivable area and lanes, and landmark models for eyes and head pose. The engineering challenge is running them on in-vehicle or roadside hardware within a strict latency and power budget, which usually means compact architectures, quantization and testing on the exact target chip. - Multi-object Tracking
Detection finds objects in one frame; tracking links them across frames, so the system knows that the pedestrian at the curb is the same one now stepping into the lane and can estimate speed and direction. Most safety decisions, such as a time-to-collision estimate, depend on tracking rather than on single-frame detection. - Sensor Fusion with LiDAR and Radar
LiDAR and radar are separate sensors, not Computer Vision, but systems often combine their distance measurements with camera images. The result is a 3D picture of the environment that improves obstacle detection and navigation, especially in poor light. Sensor fusion is used in ADAS and is central to autonomous vehicles, which must understand their surroundings to operate safely.
What Are the Challenges of Implementing Computer Vision in Real-World Transport Systems?
While the potential offered by implementing Computer Vision in transportation safety is high, realizing it in real-world systems presents many challenges. The biggest among them are:
- Data Quality
Computer Vision models need good-quality images and videos to process accurately. Real-world scenarios often include variations in light conditions, weather, and occlusions that may affect data quality and negatively affect system performance. - Integration into Existing Infrastructure
Public transportation often relies on legacy systems, which may not be technically compatible with technologically advanced Computer Vision products. Integration takes careful planning, and usually a connecting layer that passes data between old and new systems rather than a full replacement. - The Long Tail of Rare Cases
A model that handles daytime highway traffic well can still fail on a person in a wheelchair, a cyclist at dusk in rain, low sun straight into the lens, snow covering lane markings or an unusual vehicle such as a horse-drawn cart. These cases are rare in training data but are exactly where safety systems are tested. Teams build scenario catalogs, collect or simulate those conditions, and track performance per scenario rather than as one average. - Edge Hardware Limits
Safety functions must react within fractions of a second and keep working without a network connection, so models run on in-vehicle or roadside processors with limited compute and power. Every model change has to be re-validated on that hardware. - Validation and Liability
A system that influences braking or steering is subject to functional-safety and safety-of-the-intended-functionality practices in the automotive industry (ISO 26262 and ISO 21448). Even for advisory systems, such as fleet alerts, the operator needs evidence of how often the system misses events and how often it raises false alarms. - Ethical and Privacy Concerns
Cameras in public spaces and in driver cabins collect personal data. In the EU, GDPR applies to identifiable footage, and the EU AI Act prohibits real-time remote biometric identification in publicly accessible spaces for law enforcement except in narrowly defined cases. Practical safeguards include processing on the device, storing detection results instead of video where possible, blurring faces and plates in retained footage, short retention periods, and clear notice to drivers and the public.
How Are Computer Vision Safety Systems Evaluated?
They are evaluated on detection quality, timing and false-alarm rate, measured separately for each scenario that matters:
| Measure | What it tells you |
|---|---|
| Recall per scenario (e.g. pedestrian at night, cyclist crossing) | How often the system detects what it must detect |
| False alarms per hour or per 1,000 km | Whether drivers will tolerate the system or switch it off |
| Detection latency and time-to-collision at warning | Whether the warning leaves enough time to react |
| Tracking stability (ID switches) | Whether speed and direction estimates can be trusted |
| Performance by condition (light, weather, camera position) | Where the system needs more data or a fallback |
Regulatory and consumer test programs, such as the pedestrian AEB scenarios in FMVSS No. 127 or the driver-monitoring tests in Euro NCAP, are good templates even for systems that do not need certification.
Is Computer Vision in Transportation Worth Investing In for Safety Systems?
For most fleet operators and transport authorities, yes, provided the project starts from a measurable safety problem rather than from the technology. Driver monitoring, ADAS and traffic video analytics are mature, and for new vehicles in the EU and US several camera-based functions are becoming mandatory anyway. The question is usually how to use the data these systems already produce.
A practical way to decide:
- Pick the incident type that costs most, for example rear-end collisions in a delivery fleet or pedestrian conflicts at a handful of intersections.
- Check what data exists: dashcam footage, telematics events, incident reports, traffic camera feeds, and whether they can be linked by time and location.
- Define the measure of success before deployment: incidents per million miles, near-misses per week at a junction, or the share of high-risk events reviewed and coached.
- Run a limited pilot on a few vehicles or sites, compare against a similar control group, and review false alarms with the drivers or operators who receive them.
If the pilot moves the chosen measure and the people using it accept the alerts, scaling is mostly an engineering and procurement task.
Computer Vision has become an established part of transportation safety. If your transportation company already collects camera, telematics or incident data, contact Alltegrio to discuss data analytics, AI agents for operations or the labelling and review of your own image data.